Real-time granular physics, in action.
Every clip below comes out of a VeloxSim solver — NDEM for the robot work, and our open-source DEM and PBF codes for the bulk-flow and validation cases. Each is badged with the solver that produced it.
 NDEM
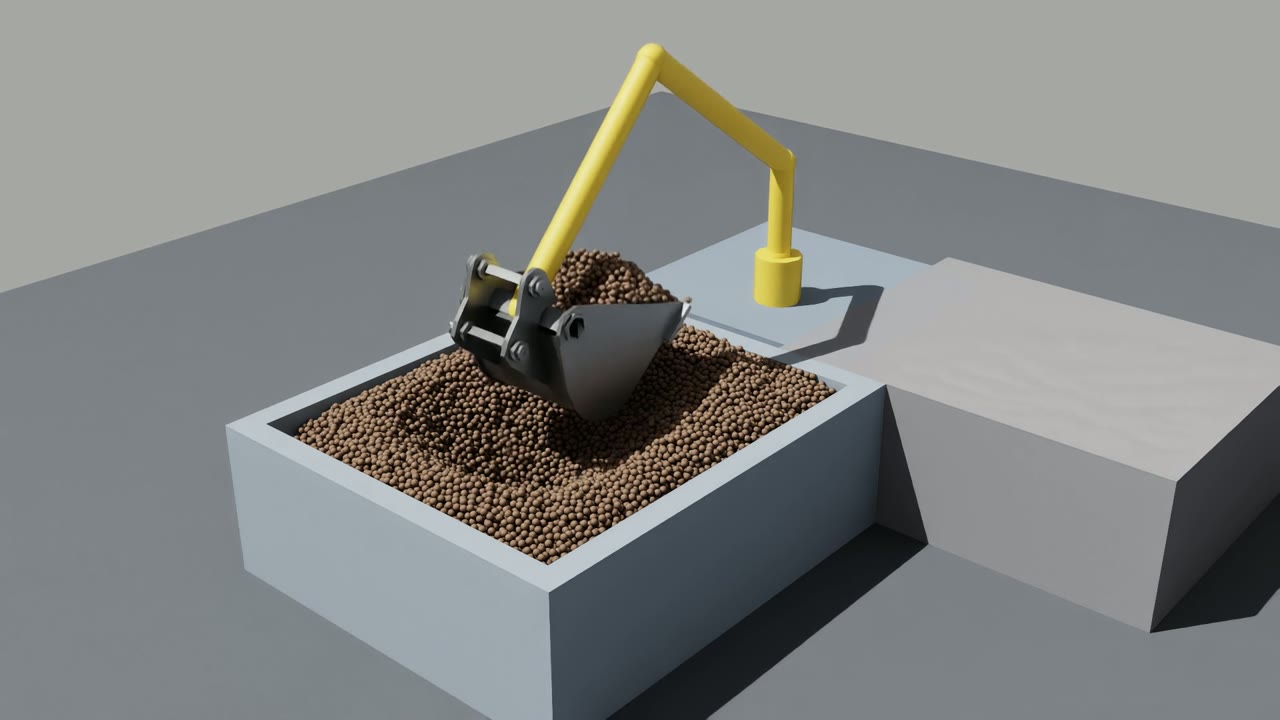
Full excavator arm — complete dig cycle
A complete excavator arm — boom, stick, and toothed bucket — moving 90,000 particles through a full dig, lift, swing, and dump. Every linkage is two-way coupled to the material through the NDEM solver; the bucket-only clips that follow strip the same scene back to isolate the material model.
 NDEM
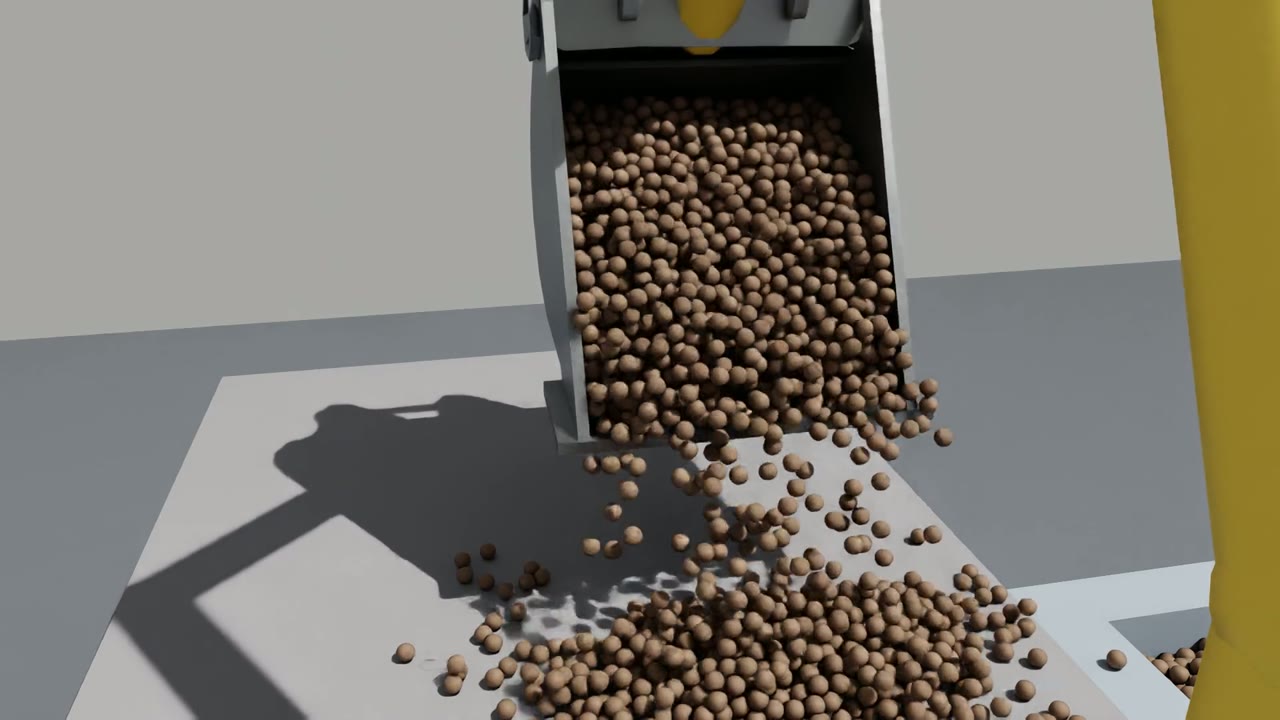
Full excavator arm — grain-scale close-up
The same 90,000-particle dig from a second camera, tight on the bucket. At this range individual grains resolve: material shears around the cutting edge, packs into the bucket, and breaks into free flight as the load tips out.
 NDEM
Excavator bucket — cohesive material
An excavator bucket working 100,000 particles with cohesion switched on. The material holds a carved face and comes away in clumps, the way damp ore or clay behaves under a bucket.
 NDEM
Excavator bucket — free-flowing material
The identical scene with cohesion switched off. The bed slumps flat and flows around the bucket instead of holding a face — the same geometry and the same robot, and only the material model changed.
 NDEM
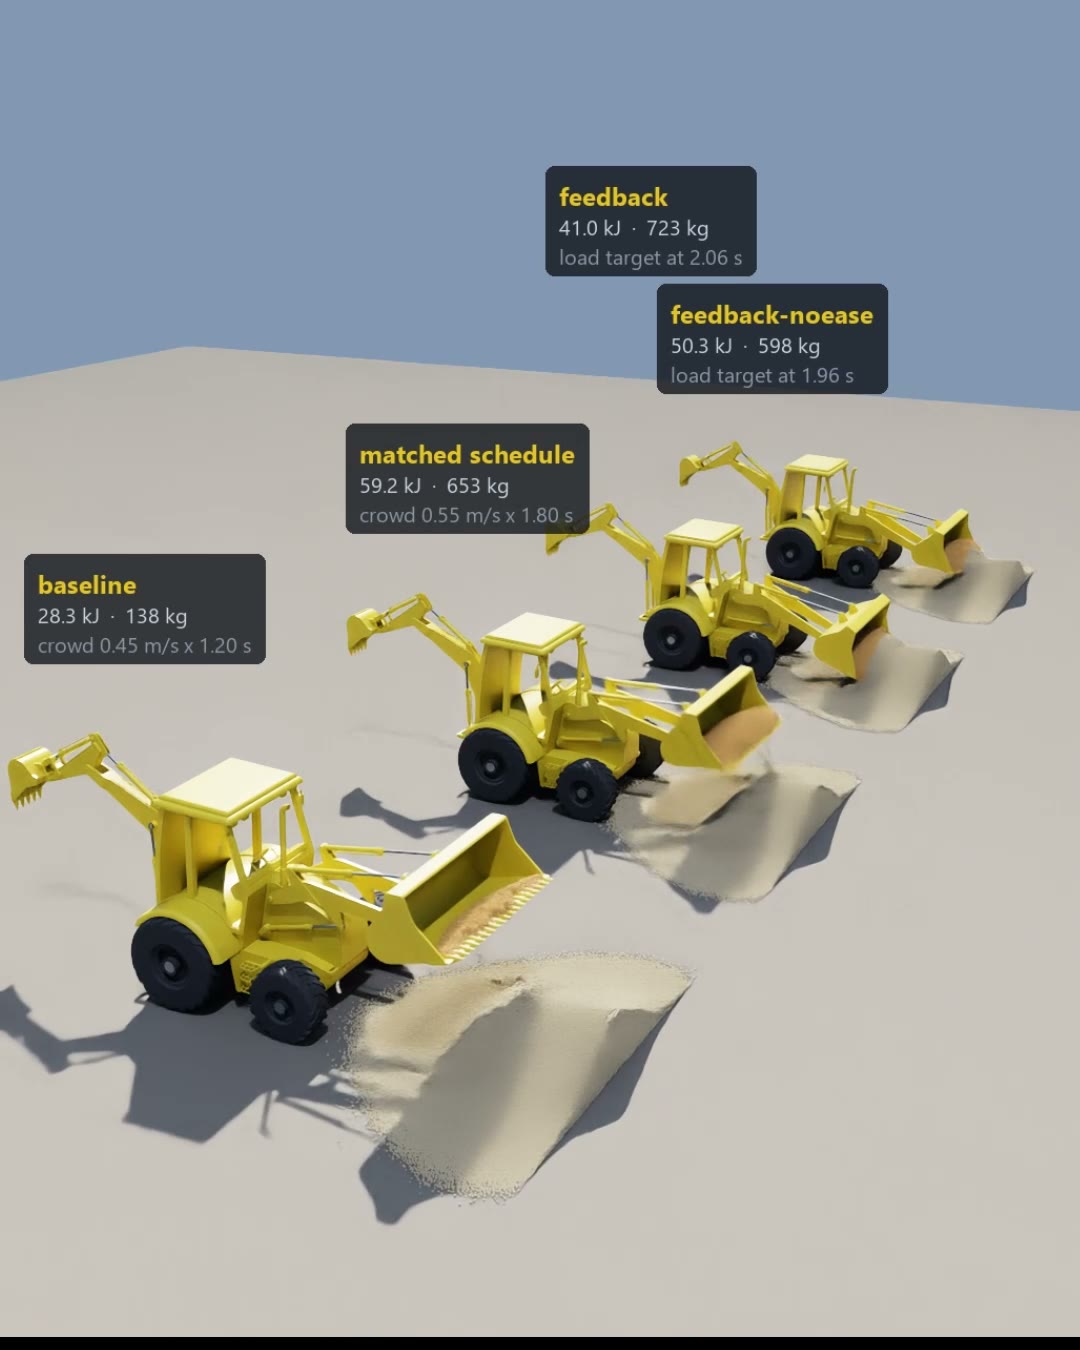
Closed-loop bucket loading, four control cases
Four wheel loaders dug together in about a million particles, each on a different controller. Watching force in the bucket rams and easing the curl won 11% more material for 31% less energy than a fixed schedule tuned to match it.
 NDEM
Autonomous scoop in granular media
A rigid scoop excavating loose material, two-way coupled through the NDEM contact solver — the exact interaction an autonomous loader has to learn.
 NDEM
Vehicle on large-scale terrain
A wheeled vehicle driving over a bed of 1.7 million grains, roughly 290,000 of them active at any moment. At this scale the solver runs at about a third of real time — the upper end of the current scale envelope.
 NDEM
Vehicle over deformable terrain
Wheeled locomotion across a granular bed — wheels sink, slip, and pile material the way real ground does under a moving robot.
 NDEM
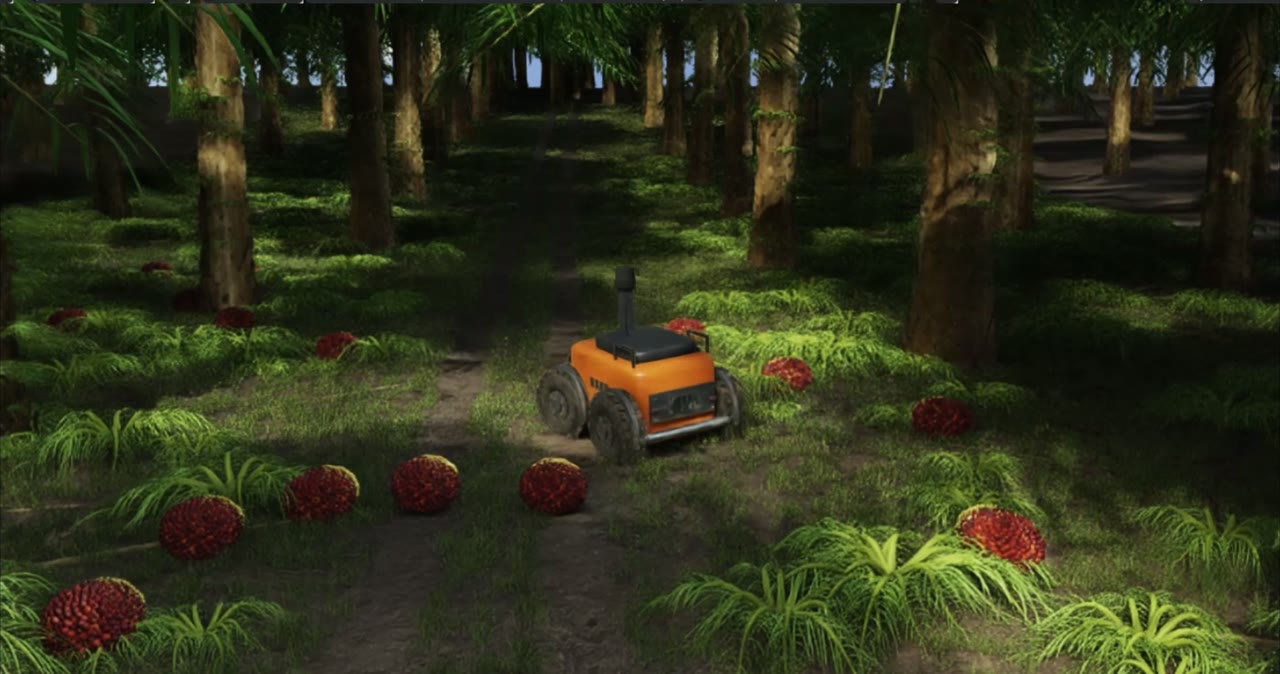
Survey rover in an oil palm plantation
A rover surveying a virtual oil palm plantation, driven by a ROS 2 control loop that senses obstacles with simulated LiDAR and logs the fruit bunches it passes. The ground is packed particles solved by NDEM, and the wheels leave tracks in it.
 DEM
Live hopper discharge
Real-time discharge of more than 50,000 particles through a hopper — mass flow, arching, and rat-holing, run on our open-source DEM solver.
 DEM
Rotating drum mixing
Granular mixing and segregation in a rotating drum — a classic DEM calibration case for cohesion, friction, and flow-regime behaviour.
 PBF
Granular dam break
A collapsing column solved with our open-source PBF solver — a standard validation case where run-out distance and final profile match physical experiments.
Robotics team doing granular simulation?
If you're building robots that dig, load, or move bulk material, send us a geometry or a scenario — we'll show you what it looks like in NDEM: real-time and calibrated to real materials.